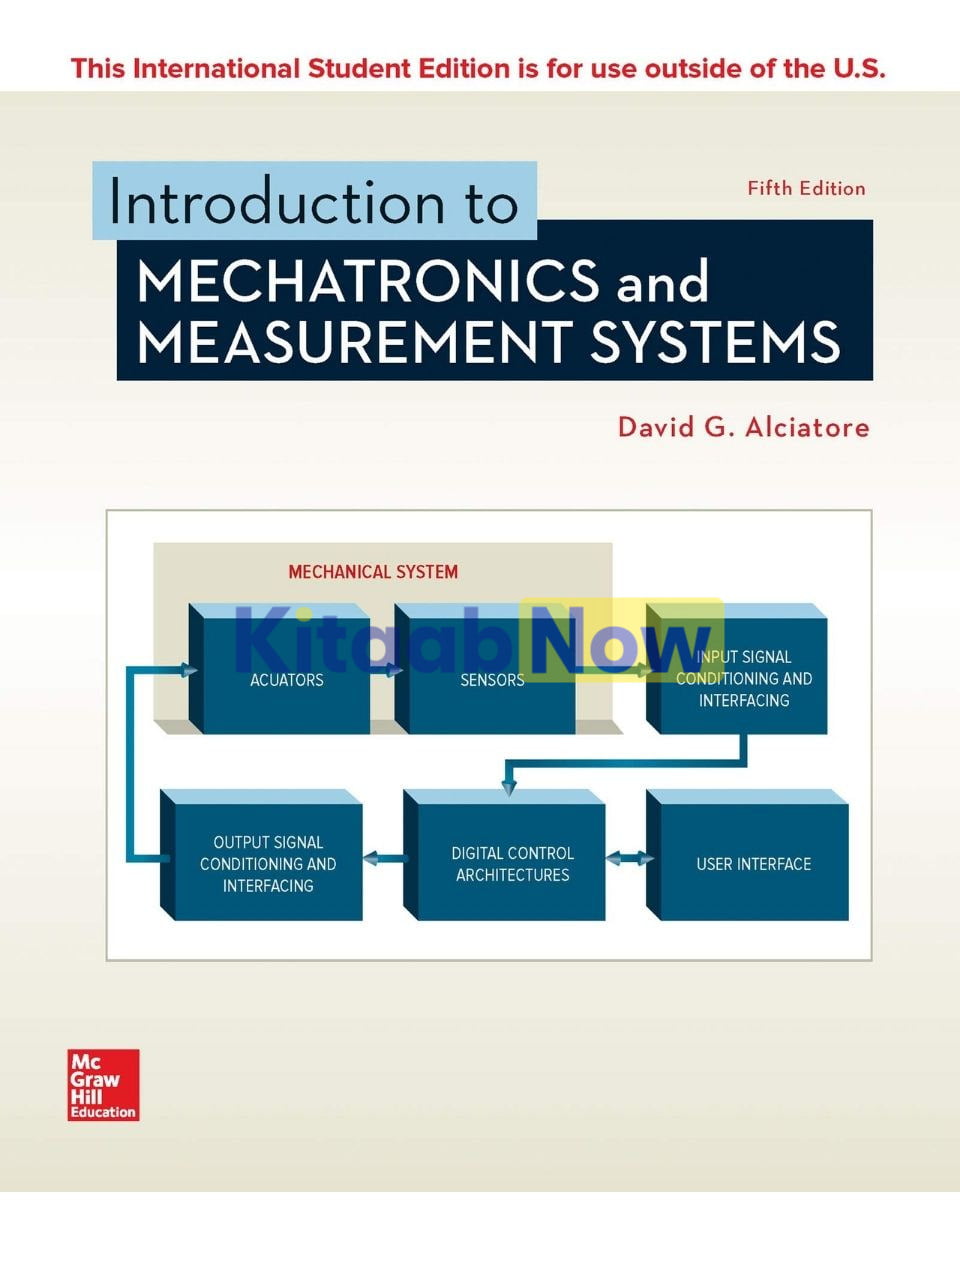
ISE Introduction to Mechatronics and Measurement Systems
- Author: David G. Alciatore
- ISBN: 9781260085198
- Publisher: McGraw Hill Education
- Edition: 5th
- Publication Date: January 11, 2018
- Format: Paperback – 588 pages
- Language: English
Out of stock
Description
Introduction to Mechatronics and Measurement Systems, Fifth Edition, provides comprehensive and accessible coverage of the field of mechatronics for mechanical, electrical and aerospace engineering majors. The author presents a concise review of electrical circuits, solid-state devices, digital circuits, and motors- all of which are fundamental to understanding mechatronic systems.
Mechatronics design considerations are presented throughout the text, and in “Design Example” features. The text’s numerous illustrations, examples, class discussion items, and chapter questions & exercises provide an opportunity to understand and apply mechatronics concepts to actual problems encountered in engineering practice. This text has been tested over several years to ensure accuracy.
Introduction to Mechatronics and Measurement Systems, Fifth Edition – is a multifaceted resource which is designed to serve as a text for modern instrumentation and measurements courses, hybrid electrical and mechanical engineering courses replacing traditional circuits and instrumentation courses, as well as for stand-alone mechatronics courses, or the first course in a mechatronics sequence. It can also work for hybrid courses, providing an opportunity to reduce the number of credit hours in a typical mechanical engineering curriculum. Written by the academic award winning author and mechanical engineering professor, Dr. David G. Alciatore.
Table of Contents
- Lists
- Class Discussion Items
- Examples
- Design Examples
- Threaded Design Examples
- Preface
- Chapter 1
- Introduction
- Mechatronics
- Measurement Systems
- Threaded Design Examples
- Chapter 2
- Electric Circuits and Components
- Introduction
- Basic Electrical Elements
- Kirchhoff’s Laws
- Voltage and Current Sources and Meters
- Thevenin and Norton Equivalent Circuits
- Alternating Current Circuit Analysis
- Power in Electrical Circuits
- Transformer
- Impedance Matching 47
- Practical Considerations
- Chapter 3
- Semiconductor Electronics
- Introduction
- Semiconductor Physics as the Basis for Understanding Electronic Devices
- Junction Diode
- Bipolar Junction Transistor
- Field-Effect Transistors
- Chapter 4
- System Response
- System Response
- Amplitude Linearity
- Fourier Series Representation of Signals
- Bandwidth and Frequency Response
- Phase Linearity
- Distortion of Signals
- Dynamic Characteristics of Systems
- Zero-Order System
- First-Order System
- Second-Order System
- System Modeling and Analogies
- Chapter 5
- Analog Signal Processing Using Operational Amplifiers
- Introduction
- Amplifiers
- Operational Amplifiers
- Ideal Model for the Operational Amplifier
- Inverting Amplifier
- Noninverting Amplifier
- Summer
- Difference Amplifier
- Instrumentation Amplifier
- Integrator
- Differentiator
- Sample and Hold Circuit
- Comparator
- The Real Op Amp
- Chapter 6
- Digital Circuits
- Introduction
- Digital Representations
- Combinational Logic and Logic Classes
- Timing Diagrams
- Boolean Algebra
- Design of Logic Networks
- Finding a Boolean Expression Given a Truth Table
- Sequential Logic
- Flip-Flops
- Applications of Flip-Flops
- TTL and CMOS Integrated Circuits
- Special Purpose Digital Integrated Circuits
- Integrated Circuit System Design
- Chapter 7
- Microcontroller Programming and Interfacing
- Microprocessors and Microcomputers
- Microcontrollers
- The PIC16F84 Microcontroller
- Programming a PIC
- PicBasic Pro
- Using Interrupts
- The Arduino Prototyping Platform
- Interfacing Common PIC Peripherals
- Interfacing to the PIC
- Serial Communication
- Method to Design a Microcontroller-Based System
- Practical Considerations
- Chapter 8
- Data Acquisition
- Introduction
- Reconstruction of Sampled Signals
- Quantizing Theory
- Analog-to-Digital Conversion
- Digital-to-Analog Conversion
- Virtual Instrumentation, Data Acquisition, and Control
- Practical Considerations
- Chapter 9
- Sensors
- Introduction
- Position and Speed Measurement
- Stress and Strain Measurement
- Temperature Measurement
- Vibration and Acceleration Measurement
- Pressure and Flow Measurement
- Semiconductor Sensors and Microelectromechanical Devices
- Chapter 10
- Actuators
- Introduction
- Electromagnetic Principles
- Solenoids and Relays
- Electric Motors
- DC Motors
- Stepper Motors
- RC Servo Motors
- Selecting a Motor
- Hydraulics
- Pneumatics
- Chapter 11
- Mechatronic Systems—Control Architectures and Case Studies
- Introduction
- Control Architectures
- Introduction to Control Theory
- Appendix A
- Measurement Fundamentals
- A.1 Systems of Units
- A.2 Significant Figures
- A.3 Statistics
- A.4 Error Analysis
- Appendix B
- Physical Principles
- Appendix C
- Mechanics of Materials
- C.1 Stress and Strain Relations
- Index
Additional information
| Weight | 0.861 kg |
|---|
Only logged in customers who have purchased this product may leave a review.
Related Products



Reviews
There are no reviews yet.